Loading...
- Home
- Visit
- Exhibit & Sponsor
- What's On
- Conference
- News
- Contact
- Show more
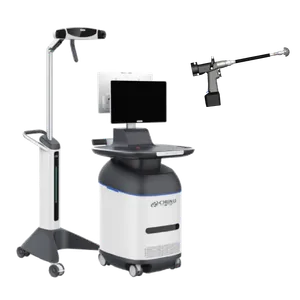
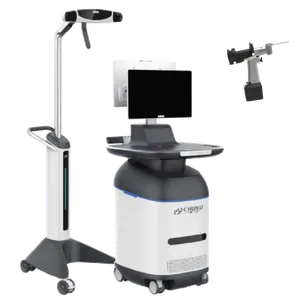
The Huanghe INS-2 Surgical Navigation System is a handheld intelligent robotic navigation system designed specifically to assist surgeons in unicompartmental knee arthroplasty (UKA). The system supports the entire surgical workflow, including preoperative and intraoperative planning, surgical plan verification, real-time visualization, navigated bone grinding, grinding depth and boundary control, and postoperative technical evaluation.
As a pioneering handheld UKA robotic system, the Huanghe INS-2 integrates intelligent navigation, autonomous perception, and precise control technologies to provide surgeons with a more accurate, efficient, and flexible surgical experience.
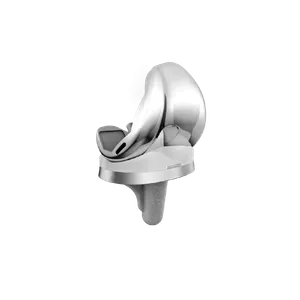
Designed for use with validated unicompartmental knee prosthesis systems, the system assists surgeons with instrument navigation and implant positioning during adult UKA procedures. Its modular design enables versatile orthopedic applications while maintaining a compact and user-friendly configuration.
Featuring intuitive software, a short learning curve, and simplified operation, the Huanghe INS-2 is designed around surgeons’ clinical needs. The handheld system eliminates the need for complex robotic setup, sterilization preparation, and large equipment installation, helping improve operating room efficiency.
With millisecond-level response for grinding boundary control and intelligent human-machine collaboration, the system supports precise bone preparation and standardized UKA procedures while providing high accessibility for different surgical environments.