Loading...
- Home
- Visit
- Exhibit & Sponsor
- What's On
- Conference
- News
- Contact
- Show more
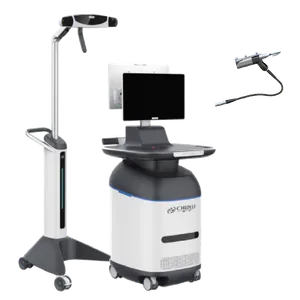
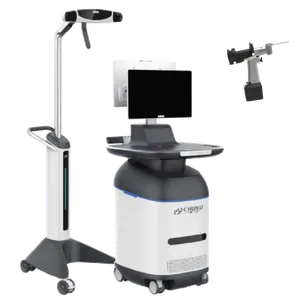
China’s First Handheld Hip Arthroplasty Robot
Changjiang INS-1 Hip Arthroplasty Surgical Navigation System is an intelligent navigation device integrated with a handheld power system. It is designed to support preoperative planning, intraoperative registration and calibration, acetabular preparation, femoral preparation verification, intraoperative positioning and navigation, intraoperative verification, and postoperative technical evaluation, assisting surgeons in performing hip arthroplasty procedures.
When used together with validated hip prostheses, this product provides navigation assistance for surgical instruments and hip implants during total hip arthroplasty procedures in adult patients.
★ Empowers surgeons with an intelligent surgical experience and supports precise surgical decision-making;
★ Short learning curve with intuitive software logic and user-friendly operation;
★ Modular orthopedic surgical robot system design supporting multiple indications and versatile clinical applications;
★ Designed with the concept of high precision, cost efficiency, and broad accessibility.
• Reduces intraoperative instrument tremor and enables a more intelligent and reliable surgical workflow;
• Eliminates the need for additional sterilization preparation for the robot and complex instrument assembly, improving efficiency and saving time;
• Minimizes operating room space requirements with a flexible layout adaptable to different surgical environments;
• Equipped with autonomous sensing and control capabilities, enabling seamless human-machine collaboration.